Dies ist eine alte Version des Dokuments!
Degree of Dispersion
The development of a physical-mathematical description of the dispersion process should, based on the present findings, not only be able to describe the deagglomeration process (erosion and rupture) but also the clustering of primary agglomerates. In order to achieve this, the processes were first modelled independently of each other. Subsequently a superimposition was carried out to reach a thorough solution.
Desagglomeration
Agglomerate Disintegration
In the following considerations, following Bolen and Colwell [BC58], it is assumed that agglomerate disintegration is a process in which a given agglomerate spontaneously breaks down into two parts of equal size under the influence of applied forces. For the disintegration process, in which two parts with a new surface area are formed as shown in the figure, work must be applied to increase the resulting polymer/agglomerate surface area.

Figure: Schematic representation of agglomerate fragmentation
For the work required to increase the surface area, the following applies to this fragmentation process, assuming an isothermal process and a brittle body [BC58] with surface energy $\sigma$:
$$\sigma_M = \frac{\dot{V}_x}{\dot{V}_z}$$
With the change in surface area over time:
$$\overline{\sigma_M} = \frac{\sum_i(\sigma_M L_{Ele})_i}{\sum_i(L_{Ele})_i}$$
the following is obtained for the dispersion efficiency into two spherical particles:
$$P = \frac{\partial W}{\partial t} = 2\sigma\pi d \frac{\partial \bar{d}}{\partial t}$$
According to Rumpf [Rum61], the surface energy is given by:
$$\sigma = \sum_{n=1}^{n_p} \sum_{k=1}^{k} \frac{F_H}{d} = n_p k \frac{\overline{F_H}}{d}$$
Here, $F_H$ denotes the effective adhesive forces, $n_p$ the number of primary particles, and $k$ the number of contact points of the primary particles in the interface to be taken into account.
The minimum power required for a disintegration process is given by:
$$P_{min} = \pi n_p k \overline{F_H} \frac{\partial \bar{d}}{\partial t}$$
In addition to the power, the stresses to which a sphere is subjected in a shear flow are considered in the next step, analogous to [Raa61], [BT74] with regard to the energy input. The particle rotates in the shear flow and is thereby subjected to alternating tensile and compressive stresses. According to Raasch [Raa61], the angular velocity $\omega$ is derived from the prevailing shear velocity of the surrounding flow:
$$\omega = \frac{1}{2} \dot{\gamma} \tag{1}$$
The power at the sphere’s surface, as shown in Figure 10.2, is formulated as follows according to Raasch [Raa61] when considering a pure shear flow:
$$P = \int_{A_{ober}} \left[\sigma_r v_r + \tau_{r\varphi} V_\varphi + \tau_{r\vartheta} V_\vartheta\right] dA$$
The following applies to the surface differential:
$$dA = r^2 \cos \vartheta \, d\vartheta d\varphi$$

Figure: Linear shear flow around a sphere [Raa61]
The stresses arising on the sphere’s surface during the rotation shown about the z-axis are (cf. [Raa61], [HFM92]):
$$\sigma_r = \frac{5}{2} \eta \dot{\gamma} \sin 2\varphi \cos^2 \vartheta$$
$$\tau_{r\varphi} = \frac{5}{2} \eta \dot{\gamma} \cos 2\varphi \cos \vartheta$$
$$\tau_{r\vartheta} = -\frac{5}{2} \eta \dot{\gamma} \sin 2\varphi \sin \vartheta \cos \vartheta$$
The following applies to the velocities:
$$v_r = \frac{\dot{\gamma}}{4} \left(2r - 5\frac{r_0^3}{r^2} + 3\frac{r_0^5}{r^4}\right) \sin 2\varphi \cos^2 \vartheta$$
$$V_\varphi = \frac{\dot{\gamma}}{4}\left[\left(r - \frac{r_0^5}{r^4}\right) \cos 2\varphi - r\right] \cos \vartheta$$
$$V_\vartheta = -\frac{\dot{\gamma}}{4} \left(r - \frac{r_0^5}{r^4}\right) \sin 2\varphi \cos 2\vartheta$$
To calculate the power resulting from the fragmentation process, we now consider the limit at the sphere’s surface for $r = r_0$. The equation then becomes:
$$P = \int_{A_{upper}} \left[\frac{5}{2} \eta \dot{\gamma} \cos 2\varphi \cos \vartheta\right] \left[-\frac{\dot{\gamma}}{2} r_0 \cos \vartheta\right] r_0^2 \cos \vartheta \, d\vartheta d\varphi$$
The figure shows the power distribution on the spherical surface.
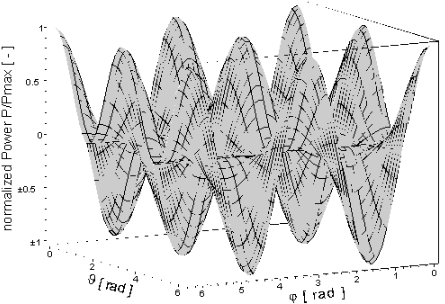
Figure: Power distribution on the spherical surface
For the process of spontaneous disintegration, the shear stress and the maximum value of the power input, as shown in Figure 10.3, are of interest, subject to the boundary condition that $\tau_{r\varphi} = \tau_{crit}$ (critical shear stress, which leads to disintegration when the cohesive forces are exceeded [BT74]), are of interest. The agglomerate is treated here as an isotropic body, so that, regardless of the surface coordinate, exceeding the critical shear stress results in spontaneous disintegration.
The maximum possible shear stress that can occur on the sphere’s surface is given by Eq. (10.16):
$$\tau_{max} = \frac{5}{2} \eta_{Fluid} \dot{\gamma}$$
The circumferential velocity is given by the equation:
$$V_\varphi = r_0 \omega = r_0 \frac{\dot{\gamma}}{2}$$
As a result of these considerations, for a sphere (agglomerate) with diameter $\bar{d}$, the maximum power that can occur is:
$$P_{max} = \frac{5}{4} \eta_{Fluid} \dot{\gamma}^2 \pi r_0^3 = \frac{5}{32} \tau_{Fluid} \dot{\gamma} \pi \bar{d}^3$$
Equating the two power expressions yields the following differential equation:
$$\frac{5}{32} \tau_{Fluid} \dot{\gamma} \pi \bar{d}^3 = 2\pi \cdot n_p k \overline{F_H} \frac{\partial \bar{d}}{\partial t}$$
If we consider the interface of the agglomerate, the number of particles at this interface depends on the surface porosity. The surface porosity $\psi_F$ is calculated according to [PEW93] as the ratio of the area $A_H$ not occupied by the solid to the total area $A$:
$$\psi_F = \frac{A_H}{A} = 1 - \frac{n_p A_p}{A}$$
From this equation, it is possible to derive a relationship for calculating the number of particles in the interface as a function of the surface porosity and the mean agglomerate diameter:
$$n_p = (1 - \psi_F) \frac{A}{A_p} = (1 - \psi_F) \frac{\bar{d}^2}{d_p^2}$$
Substituting the values gives the equation:
$$\frac{5}{32} \tau_{Fluid} \dot{\gamma} \pi \bar{d} = 2(1 - \psi_F) \frac{1}{d_p^2} k \pi \overline{F_H} \frac{\partial \bar{d}}{\partial t}$$
The considerations outlined so far apply to shear fractures in a pure shear flow. However, this does not occur in extruders; rather, in fully filled screw sections, there is always a superposition of compressional and drag flow. Here, the superposition of a pressure gradient in a screw channel results in a shift in the stress state, as shown in Figure 10.4 (Mohr’s stress circle). Accordingly, under sufficiently high pressures, fragmentation can no longer occur under tensile stress. Since experiments have shown agglomerate disintegration particularly in pressurised zones, shear stresses are therefore responsible for the disintegration processes. In partially filled screw sections, too, one is dealing with a multidimensional flow.
Tensile strength, as a material property, may only be used in the case of pure cleavage fractures. For a cleavage fracture perpendicular to the principal tensile stress, the normal stress hypothesis applies. However, this cannot be applied, as pressures significantly higher than the agglomerate strength typically occur in the melt. The extended shear stress hypothesis is appropriate here. It assumes different yield shear stresses. The envelope of the corresponding Mohr’s stress circles is then the yield strength $\tau = f(\sigma)$ [Dub91]. This represents a comprehensive material characteristic. Here, due to incomplete material properties, the envelope is replaced by three straight lines (Figure 10.4).
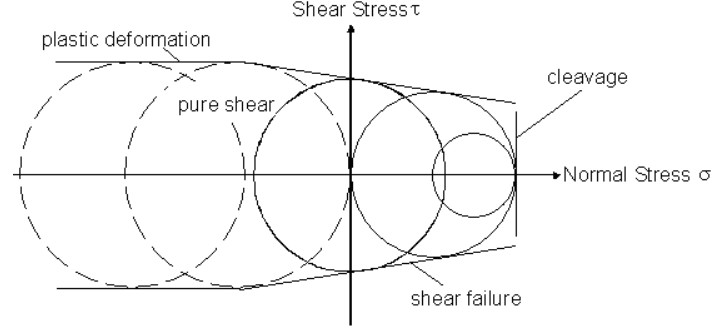
Figure: Limiting agglomerate strength according to Mohr [Dub91]
Due to the high pressures occurring in continuous mixers, shear failures are more than likely to occur. From this follows:
$$\tau_{Sch} = \frac{1}{2} \sigma_v = \sigma_3 - \sigma_1 \tag{10}$$
With σ1 and σ3 being the maximum principle stresses. We assume the hoop stress σv to be almost equal to the tensile strength σz, which we predict using Rumpf's [Rum61] equation:
$$\tau_{Sch} = \frac{1}{2} \sigma_z = \frac{(1 - \varepsilon_A) \overline{F_{adh}}}{2\pi \cdot d_p^2} \tag{11}$$
Inserting the agglomerate strength according to Rumpf (eqn. (11) results in the following differential equation for the agglomerate rupture:
$$\frac{\partial \bar{d}}{\partial t} = \frac{5}{64} \cdot \frac{\tau_{Fluid} \cdot \dot{\gamma}}{\tau_{Sch} \cdot \pi} \cdot \bar{d} \tag{12}$$
Erosion
In order for primary particles to break away (erode) from the agglomerate, the shear stresses acting on them must overcome the adhesive forces of the primary particles bound to the surface of the agglomerate.

Figure: Schematic representation of erosion
The power required to detach individual particles from an agglomerate results, as with fragmentation, from the creation of new surfaces. The power for the erosion process under consideration can be expressed as follows, in accordance with the figure:
$$P = \sigma \frac{\partial A}{\partial t}$$
The surface area of an agglomerate consisting of primary particles with diameter $d_P$ is approximately:
$$A = n_0 \pi \frac{d_p^2}{2}$$
To calculate the number of primary particles $n_0$ on the surface of the agglomerates, it is assumed that the primary particles are uniformly distributed throughout the agglomerate and that the porosity at the surface is therefore the same as the porosity at any cross-section:
$$n_0 \pi \frac{d_p^2}{2} \cong (1 - \psi_F) \pi \bar{d}^2$$
$$n_0 = \frac{2(1 - \psi_F) \bar{d}^2}{d_p^2}$$
It follows that for the change over time in the surface area of an agglomerate from which particles are removed from the outer shell:
$$\frac{\partial A}{\partial t} = \pi (1 - \psi_F) \bar{d} \frac{\partial \bar{d}}{\partial t}$$
The minimum power required for erosion is therefore:
$$P_{min} = \sigma \pi (1 - \psi_F) \bar{d} \frac{\partial \bar{d}}{\partial t}$$
Here, too, the power is equated with the maximum instantaneous power delivered by the fluid:
$$\frac{5}{32} \tau_{Fluid} \dot{\gamma} \pi \bar{d}^3 = \sigma \pi (1 - \psi_F) \bar{d} \frac{\partial \bar{d}}{\partial t}$$
If we now substitute the equation for the surface energy into the equation, analogous to the fragmentation, we obtain:
$$\frac{5}{32} \tau_{Fluid} \dot{\gamma} \bar{d} = 2n_0 k \overline{F_H} (1 - \psi_F) \frac{\partial \bar{d}}{\partial t}$$
Using the number of primary particles on the surface of an agglomerate (spherical in shape), we obtain:
$$\frac{5}{64} \tau_{Fluid} \dot{\gamma} \bar{d} = 2 \frac{(1 - \psi_F)}{\bar d_p^2} k \overline{F_H} (1 - \psi_F) \frac{\partial \bar{d}}{\partial t}$$
If we substitute the shear strength defined above, the following results for the erosion process:
$$\frac{\partial \bar{d}}{\partial t} = \frac{5 \tau_{Fluid} \dot{\gamma}}{256 \pi (1 - \psi_F) \tau_{Sch}} \bar{d}$$
Clustering
Clustering is essentially the collision of particles. In order for particles to collide, two conditions must be satisfied:
- The particles must move at different velocities.
- Assuming that all the particles are approximately spherical, the distance between the particles must be smaller than or the same as the sum of their radii.
The following remarks on cluster formation refer to a differential volume element $V$ containing $n_A$ agglomerates.
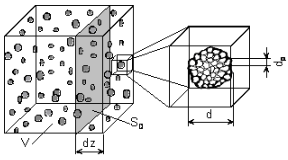
Figure: Differential volume element
Assuming that the agglomerates have similar mean spherical diameters at the same times, a monitoring cross-section can be defined for the agglomeration process, within which agglomerates can come into contact:
$$S_{üb} = \frac{\pi}{4} (d_M + d)^2$$

Figure: Definition of the monitoring cross-section
If we now apply this analysis to a slice of the volume element with length $\partial z$ and cross-sectional area $S_D$, there are $\partial n_A$ agglomerates within this slice:
$$\partial n_A = n_A \frac{S_D \partial z}{V}$$
In relation to the monitoring cross-section, this yields a differential number of agglomerates $n_M$ that may experience a collision:
$$\partial n_M = \frac{\partial n_A S_{mon}}{S_D}$$
Substituting the equations, we obtain:
$$\partial n_M = n_A \frac{\pi (d_M + d)^2}{4 V} \partial z$$
By substituting the solid concentration
$$c_F = \frac{V_F}{V}$$
and the solid volume
$$V_F = n_{A0} V_{A0}$$
we obtain an expression for the rate of change of the number of particles in the volume element:
$$\frac{\partial n_M}{\partial t} = \frac{\partial}{\partial t} \left(\frac{n_A \pi \left(\bar{d}_0 + \bar{d}\right)^2}{n_{A0} 4 V_{A0}} c_F \partial z\right)$$
The number $n_a$ of particles participating in the agglomeration is given by the ratio of the particle volume at time $t > t_0$ to the particle volume at time $t = t_0$:
$$n_a = \frac{\bar{V}_A}{\bar{V}_{A0}} = \frac{\pi \bar{d}^3}{6 \bar{V}_{A0}}$$
Since the essential process in the agglomeration of particles is collision transfer, the change in the number of particles undergoing a collision must be equal to the change in the number of particles participating in the agglomeration. This yields:
$$\frac{\partial n_M}{\partial t} = \frac{\partial n_a}{\partial t}$$
Substituting
$$\frac{\partial n_a}{\partial t} = \frac{\pi 1 \partial \bar{d}^3}{6 \bar{V}_{A0} \partial t}$$
we obtain:
$$\frac{\partial \bar{d}^3}{\partial t} = \frac{3 n_A}{2 n_{A0}} c_F \left(\bar{d}_0 + \bar{d}\right)^2 \frac{\partial z}{\partial t}$$
Since the solid mass in the volume element does not change over time as the agglomerates coalesce, the ratio of the number of particles can be calculated from a mass balance:
$$\frac{n_A}{n_{A0}} = \frac{\bar{d}^3}{\bar{d}_0^3}$$
For two agglomerates to collide, it must also be ensured that there is a relative velocity between the two particles:
$$\bar{v}_{z,rel} = \frac{\partial z}{\partial t}|_{avg} = \frac{1}{2} (v_2 - v_1)$$
If we now derive an expression for the shear velocity of the surrounding fluid
$$\dot{\gamma} = \frac{\partial v_z}{\partial y} = \frac{2(v_2 - v_1)}{(\bar{d}_0 + \bar{d})}$$
and substitute this, we obtain the average relative velocity:
$$\frac{\partial z}{\partial t}|_{avg} = \bar{v}_{z,rel} = \frac{1}{4} \dot{\gamma} (\bar{d} + \bar{d}_0)$$
Substituting gives:
$$\frac{\partial \bar{d}^3}{\partial t} = \frac{1 \bar{d}^3}{8 \bar{d}_0^3} c_F \dot{\gamma} \left(\bar{d}_0 + \bar{d}\right)^2$$
If, analogous to the dispersion analyses by Bolen and Colwell [BC58], it is assumed that only two agglomerates adhere to each other at any one time, the diameter of the agglomerate after cluster formation is given by:
$$\bar{d} = \sqrt[3]{2} \bar{d}_0$$
Finally, introducing the simplification yields the differential equation describing the cluster formation process:
$$\frac{\partial \bar{d}}{\partial t} = \frac{1}{8} \left(1 + \sqrt[3]{2}\right) c_F \dot{\gamma} \bar{d}$$
Superimposition of Clustering and Breakdown Models
Which of the three cases discussed above occurs in a given section of a processing machine depends essentially on the shear stress level and the strength of the agglomerates. Three cases must be distinguished here:
- Case 1:
If the shear stress level is below the critical shear stress for erosion, no deagglomeration will be observed. Agglomerates will clump together. The average agglomerate diameter will increase over time. This case will be observed primarily at very low shear stresses or with agglomerates having very high tensile strength, e.g. due to solid bridges.
- Case 2:
If the shear stress in the range under consideration lies above the critical shear stress for erosion but below the critical shear stress for fragmentation, it will be observed that individual particles detach from the agglomerate surface. However, no fragmentation of the agglomerates will be observed. The process of erosion is superimposed on the process of cluster formation in this case.
- Case 3:
If shear stresses exceeding the yield stress for agglomerate break-up are observed, it is to be expected that, on the one hand, the agglomerates will break up and, on the other hand, particles will detach from the agglomerate surface. Here too, it is to be expected that the deagglomeration process is superimposed by an agglomeration process.
A closed-form solution incorporating all three cases can now be obtained from the superposition of the individual processes. If the differential equations describing cluster formation and agglomerate disintegration are superimposed, a differential change in diameter with time results from the sum of the changes in the individual processes:
$$\frac{\partial \bar{d}}{\partial t} = \left(\frac{\partial \bar{d}}{\partial t}\right)_{cluster formation} - \left(\frac{\partial \bar{d}}{\partial t}\right)_{disintegration} - \left(\frac{\partial \bar{d}}{\partial t}\right)_{erosion}$$
To solve the equation, the following dimensionless parameters are defined, which result from the individual processes:
Dimensionless mean agglomerate diameter:
$$d^x = \frac{\bar{d}}{\bar{d}_0}$$
Dimensionless exposure time:
$$t^x = \dot{\gamma} t$$
Disintegration constant:
$$C_{Ze} = \frac{5}{128 \pi}$$ Cluster formation constant:
$$C_{Cl} = \frac{1}{8} \left(1 + \sqrt[3]{2}\right)$$
Erosion constant:
$$C_{Er} = \frac{5}{256 (1 - \psi_F) \pi}$$
Dimensionless stress:
$$\pi_B = \frac{\tau_{Fluid}}{\tau_{Sch}}$$
Applying the dimensionless parameters yields the normalised differential equation:
$$\frac{\partial d^x}{\partial t^x} = C_{Cl} c_F d^x - (C_{Er} + C_{Ze}) \pi_B d^x$$
With the boundary condition that the initial agglomerate diameter
$$d^x (t = t_0 = 0) = 1$$
is, the solution is
$$d^x(t^x) = \exp\{(C_{Cl} c_F - (C_{Er} + C_{Ze}) \pi_B) t^x\}$$
When applying this relationship, the distinction between cases defined above must be taken into account. If the critical shear stresses for erosion or agglomerate fragmentation are not reached during application, the respective dimensionless constants $C_{Ze}$ and $C_{Er}$ in the equations must be set to zero. The limiting shear stresses depend on the specific application (polymer-filler combination) and cannot be specified in general terms [Rum75], [Kre64]. In addition to the yield shear stress, according to Martin [Mar72], a minimum stress duration must be taken into account depending on the specific application, below which no fragmentation can occur even if the yield shear stress is exceeded.
Discussion and Results
The figure shows the dimensionless mean diameter versus the dimensionless stress and the dimensionless exposure time for three different solids volume concentration.
When looking at a particular case (see case 1) of the three diagrams, in which no agglomerate dispersion takes place, but the agglomerates form clusters, it becomes evident that the speed, at which the agglomerates form clusters is dependent solely on the solids volume concentration and the stress exposure time.
If there is a shear stress between the critical shear stress for erosion and the critical shear stress for agglomerate rupture, (see case 2), it can be observed that, apart from a dependence upon the dimensionless time and the solids volume concentration, there is also a dependence upon the dimensionless stress.
In the case of shear stresses above the critical shear stress for agglomerate rupture (see case 3), the agglomeration, erosion and rupture processes have to be superimposed to get a the description. Obviously the volume concentration of the solid influences the profile of the dimensionless diameter over the dimensionless time but only if the dimensionless stress is low. While the dimensionless diameter decreases relatively slowly in the case of high solid concentrations, a much more rapid decrease can be observed in the case of low solid volume concentrations.
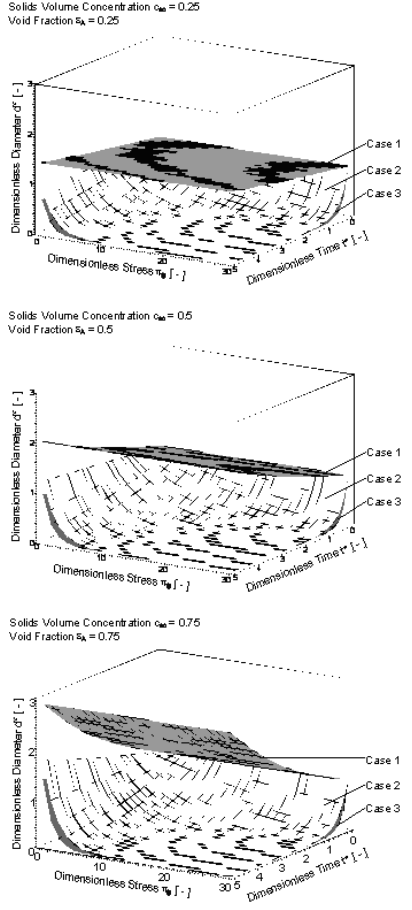
Figure: Dimensionless agglomerate diameter vs. dimensionless time and dimensionless stress for different solid volume concentrations.
In order to discuss the results further, it is necessary at this point to define the critical solid volume concentration. Setting $d^*(t^*)=const.=1$ describes the critical solids concentration, at which there is neither an increase nor a decrease in the diameter of the particle.
$$C_{F,krit} = \frac{C_{Er} + C_{Ze}}{C_{Cl}} \pi_B \tag{1}$$
The diagram in the figure shows the critical solids concentration against the dimensionless stress and the agglomerate porosity. The area in which the agglomeration dominates the deagglomeration is situated on the upper side of the plot.
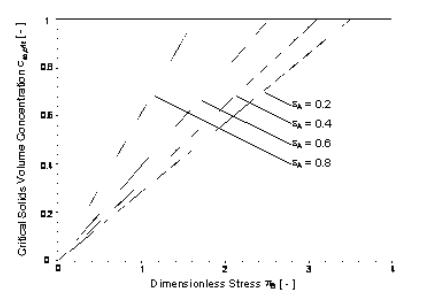
Figure: Critical solid volume concentration vs. dimensionless stress.
Here, too, it is theoretically possible that cluster formation outweighs agglomerate fragmentation. It can be seen that the region in which agglomerate aggregation dominates reaches the physical maximum value of the critical volume concentration even at a very low dimensionless stress. If one takes into account that, due to the different densities of the filler and the plastic melt, the mass concentration is significantly greater than the volume concentration, it can be assumed that, in this case, agglomerate fragmentation dominates over cluster formation and agglomerate breakdown effectively occurs. The porosity of the agglomerates, which is incorporated into the erosion constant, also plays a role in this context.
The physical model is capable of describing the effects of dispersion (erosion, agglomerate fragmentation, agglomeration) described in the literature by superimposing the physical models of the individual effects, which were also developed in this work.
References
[BC58] Bolen W.R.; Colwell, R.E.: Soc. Plast. Eng. 1958; 14: 24-28
[BT74] Bagster D.F., Tomi, D.: The stresses within a sphere on simple flow fields, Chemical Eng. Science 1974; 29: 1773-1783
[Dub91] Dubbel, Taschenbuch des Maschinenbaus, 1991
[HFM92] Horwatt, S., Feke, D., Manas-Zlocyower, I.: The influence of structural heterogeneities on the cohesivity and breakup of agglomerates in simple shear flow, Powder Technology 1992; 72: 113-119
[Kre64] Krekel J.: Herstellung und Messung von Scherströmungen mit extrem großer Schubspannung und ihr Einfluss auf die Zerkleinerung von Agglomeraten, 1964
[Mar72] Martin G.: Untersuchung der Homogenisierfunktion von Einschneckenextrudern für die Kunststoffverarbeitung, 1972
[Pah89] Pahl MH.: Lagern, Fördern und Dosieren von Schüttgütern, Verlag TÜV Rheinland, 1989
[Raa61] Raasch J.: Beanspruchung und Verhalten suspendierter Festsstoffteilchen in Scherströmungen hoher Zähigkeit, 1961
[Rum61] Rumpf H.: Agglomeration, Intern. Symposium Philadelphia 1961: 379-418
[Rum75] Rumpf H.: Mechanische Verfahrenstechnik, München, Wien: Carl Hanser Verlag, 1975