Dies ist eine alte Version des Dokuments!
Strand Cooling
From SIGMA version 11.1, it is possible to model a strand cooling. The temperature distribution within a polymer strand can be determined related to specific times. With the help of the strand cooling, the dimensioning of the cooling length can be significantly simplified and conclusions can be drawn on the necessary cooling times.
The temperature distribution is determined via the Finite Difference Method (FDM). Complex thermal conductions can be represented by the Fourier differential equation (see Equation 3). In the case of FDM, the partial derivatives are simplified as a difference quotient and so an approximate solution of the problem can be calculated. For the modelling, the present geometry is discretized and temperatures can be calculated for the interpolation points [FP08], [Mar11].
Discretization
The molten strand is led out of the screw tip into the process water and in doing so it is cooled convectively (see Figure 1). Within the water, there is always the same defined strand length.
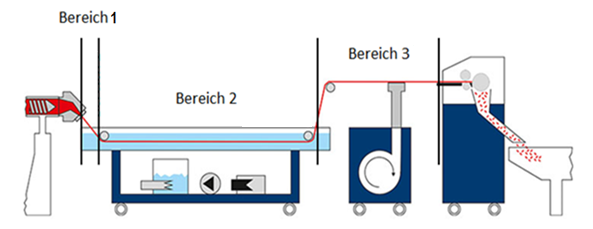
Figure 1: Exemplary strand cooling with additional strand extraction and granulation
In order to determine the temperature distribution over the strand length and the strand cross-section, it is discretized as follows:
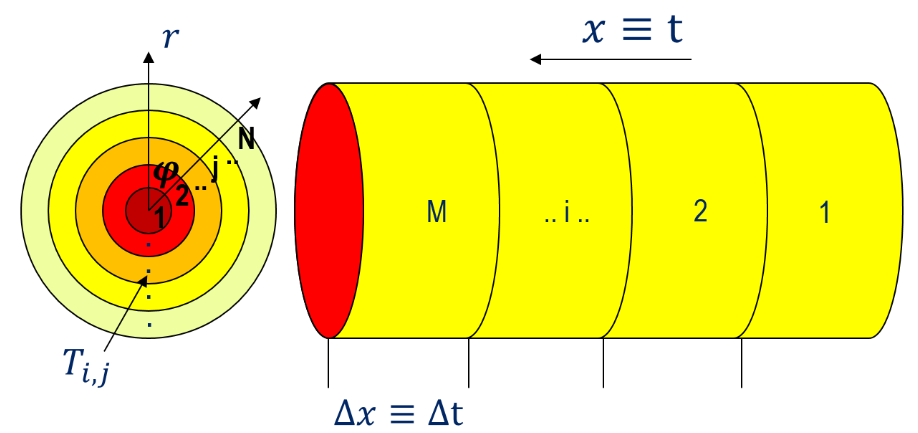
Figure 2: Discretization strand
In the length direction, the strand is divided into M segments with the running index i. Since the time is relevant for the unsteady heat conduction, it is described over the cooling length L and the line speed v.
The index i stands for any position x, at which the strand has already been in contact with the water for a specific time t. The length of the individual subintervals in the length direction can be determined with:
$$\Delta x = \frac{L}{M} \tag{Equation 1}$$
Further, the cross section in radial direction is divides into N segments with the index j. The subintervals with the radius of the strand R results to:
$$\Delta r = \frac{R}{N} \tag{Equation 2}$$
Therefore, the relevant temperatures have two indices ($T_{i,j}$) and are located in the middle of the defined intervals, see Figure 2.
Determination of the temperature field
To determine the time-related temperature fields within a solid, the Fourier differential equation is considered (here in cylinder coordinates) [VDI06]:
$$\rho c_p \frac{\partial T}{\partial t} = -\lambda \left[\frac{\partial^2 T}{\partial r^2} + \frac{1}{r} \frac{\partial T}{\partial r} + \frac{1}{r^2} \frac{\partial T}{\partial \varphi^2} + \frac{\partial^2 T}{\partial z^2}\right] \pm \dot{q}_s \tag{Equation 3}$$
For the current problem (viz. no external heat source, no angular temperature gradient), the differential equation is simplified as follows:
$$\frac{\partial T}{\partial t} = \frac{\lambda}{\rho \cdot c_p} \cdot \left[\frac{\partial^2 T}{\partial r^2} + \frac{1}{r} \frac{\partial T}{\partial r}\right] \tag{Equation 4}$$
The finite difference method provides an approximate solution, whereby the introduced error can be minimized by increasing the degree of discretization. However, this also increases the calculation effort. To approximate the partial derivatives, a Taylor series development is performed.
A Taylor series expansion is carried out to approximate the partial derivatives: The development of the temperature for a small time step results in [BK97]:
$$T_{t+\Delta t,r} = T_{t,r} + \frac{\partial T}{\partial t} \Delta t + \cdots \tag{Equation 5}$$
The Taylor series development is broken off after the first member, resulting in
$$\frac{\partial T}{\partial t} = \frac{T_{t+\Delta t,r} - T_{t,r}}{\Delta t} \tag{Equation 6}$$
The first of the three partial derivatives is approximated with
$$\frac{\partial T}{\partial t} = \frac{T_{t+\Delta t,r} - T_{t,r}}{\Delta t} = \frac{T_{i+1,j} - T_{i,j}}{\Delta t} \tag{Equation 7}$$
A Taylor series development of the temperature in the radial direction with truncation after the second element results in the following [BK97]:
$$T_{i,j+1} = T_{i,j} + \frac{\partial T}{\partial r} \Delta r + \frac{1}{2} \frac{\partial^2 T}{\partial r^2} \Delta r^2 + \cdots \tag{Equation 8}$$
$$T_{i,j-1} = T_{i,j} - \frac{\partial T}{\partial r} \Delta r + \frac{1}{2} \frac{\partial^2 T}{\partial r^2} \Delta r^2 + \cdots \tag{Equation 9}$$
These two equations are added together:
$$\frac{\partial^2 T}{\partial r^2} = \frac{T_{i,j+1} - 2T_{i,j} + T_{i,j-1}}{\Delta r^2} \tag{Equation 10}$$
Substituting equation 10 into equation 8 or equation 9 yields:
$$\frac{\partial T}{\partial r} = \frac{T_{i,j+1} - T_{i,j-1}}{2 \cdot \Delta r} \tag{Equation 11}$$
This determines all partial derivatives approximately. Inserting them into equation 4 gives the following result:
$$\frac{T_{i+1,j} - T_{i,j}}{\Delta t} = a \left[\frac{T_{i,j+1} - 2T_{i,j} + T_{i,j-1}}{\Delta r^2} + \frac{1}{r} \frac{T_{i,j+1} - T_{i,j-1}}{2 \cdot \Delta r}\right] \tag{Equation 12}$$
After a few simplifications, the following expression results:
$$T_{i+1,j} = T_{i,j} + \frac{\Delta t \cdot a}{R^2} \left[(T_{i,j+1} - 2T_{i,j} + T_{i,j-1}) \cdot N^2 + \frac{N}{j} \cdot \frac{T_{i,j+1} - T_{i,j-1}}{2}\right] \tag{Equation 13}$$
In addition, the time difference Δt can be described by the ratio of the length to the pull-off speed:
$$T_{i+1,j} = T_{i,j} + \frac{\Delta x \cdot a}{v_{ab} \cdot R^2} \left[(T_{i,j+1} - 2T_{i,j} + T_{i,j-1}) \cdot N^2 + \frac{N^2 T_{i,j+1} - T_{i,j-1}}{j \cdot 2}\right] \tag{Equation 14}$$
$$T_{i+1,j} = T_{i,j} + \frac{\Delta x \cdot a \cdot N^2}{v_{ab} \cdot R^2} \left[(T_{i,j+1} - 2T_{i,j} + T_{i,j-1}) + \frac{1}{j} \frac{T_{i,j+1} - T_{i,j-1}}{2}\right] \tag{Equation 14.1}$$
For each shell j, the material-specific properties are determined in each time step i depending on the temperature.
It can be seen that the temperature can be determined on the basis of three temperatures that are located in the preceding length segment i. If the temperature is to be determined in the last radial segment at j=N, there is no preceding temperature with the index j+1; similarly, there is no preceding temperature with j-1 in the middle of the line. Accordingly, boundary conditions must be defined for these limiting cases in order to calculate auxiliary temperatures.
Boundary conditions
It is assumed, that the initial strand temperature is constantly distributed over the cross section and corresponds to the temperature at the screw tip.
$$T_{0,j} = T_M \text{ for all j} \tag{Equation 15}$$
Boundary condition inside the strand
For all radial segments with index j=1, it is assumed that the two predecessor temperatures $T_{i,j}$ und $T_{i,j-1}$ are the same. The Taylor series development is broken off after the first member, resulting in equation 6:
$$T_{i+1,1} = T_{i,1} + \frac{\Delta x \cdot a}{v_{ab} \cdot R^2} \cdot (T_{i,2} - T_{i,1}) \cdot \frac{3}{2} \cdot N^2 \tag{Equation 16}$$
Boundary condition at strand surface
In the last radial segment j=N is no previous temperature with index j+1. Therefore, an auxiliary temperature is needed, which is linked to the water temperature. For this purpose, an auxiliary layer is defined, which is a step size (Δr) behind the last segment and represents the index j + 1.
The calculated temperatures are always at the core of the segments, see figure 2. This means für j=N, that the last segment is not the surface temperature. The surface is displaced by the length Δr/2.
To determine the temperature in the auxiliary layer, a boundary condition of the third kind (or Newton boundary condition) is considered, which is used for the convective heat transfer. The respective auxiliary temperature can be determined graphically, see figure 3. A Taylor series development of the temperature in the radial direction with truncation after the second element results in the following: [BK97]; [VDI06]
$$T_{i,Hilfs.} = T_{i,N} + \frac{\Delta r}{\frac{\lambda}{\alpha} + \frac{\Delta r}{2}} \cdot (T_U - T_{i,N}) \tag{Equation 17}$$
The distance is calculated from the equilibrium between the heat flow emitted to the environment and the heat flow supplied by the strand via heat conduction, compare [BK97]. For the calculation of the heat transfer coefficient and the therefor required Nusselt number, the case of a moving cylinder in a resting fluid with the assumption Pr = 10 is used [VDI06].
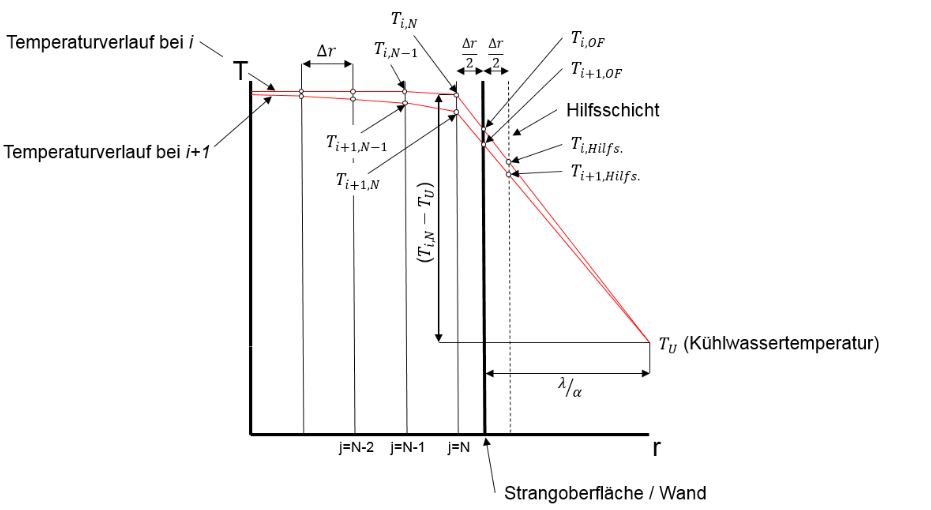
Figure 3: Exemplary temperature curves at I and i+1
Convergence criterion
Based on the Binder-Schmidt method (see [BK97]), the following boundary is defined for the factor (Fourier number) from equation 18:
$$\frac{\Delta t \cdot a}{\Delta r^2} \leq \frac{1}{2} \tag{Equation 18}$$
The following minimum value is specified for the axial number of segments:
$$M_{min} = N^2 \cdot 2 \cdot \frac{\lambda}{\rho \cdot c_p} \cdot \frac{L}{v_{ab} \cdot R^2} \tag{Equation 19}$$
Calculation of the output
After the calculation of the cooling length, SIGMA displays different temperatures. These temperatures are calculated as follows:
Core temperature:
$$T_{i,Mitte} = T_{i,1} \tag{Equation 18}$$
Surface temperature:
$$T_{i,OF} = \frac{(T_{i,N} + T_{i,Hilfs.})}{2} \tag{Equation 19}$$
Mean temperature:
$$T_{i,Mittel} = \frac{2}{N^2 + N} \cdot \sum_{j=1}^N j \cdot T_{i,j} \tag{Equation 20}$$
References
[BK97] Bosnjakovic, F.; Knoche, K. F.: „Technische Thermodynamik Teil II„; Dr. Dietrich Steinkopff Verlag, GmbH & Co. KG; Darmstadt; 1997
[FP08] Ferziger, J. H.; Peric, M.: „Numerische Strömungsmechanik“; Springer-Verlag Berlin Heidelberg; 2008
[Mart11] Martin, H.: „Numerische Strömungssimulation in der Hydrodynamik„; Springer-Verlag Berlin Heidelberg; 2011
[VDI06] Verein Deutscher Ingenieure: „VDI – Wärmeatlas“; Springer-Verlag Berlin Heidelberg; 2006